Depth Any Panoramas
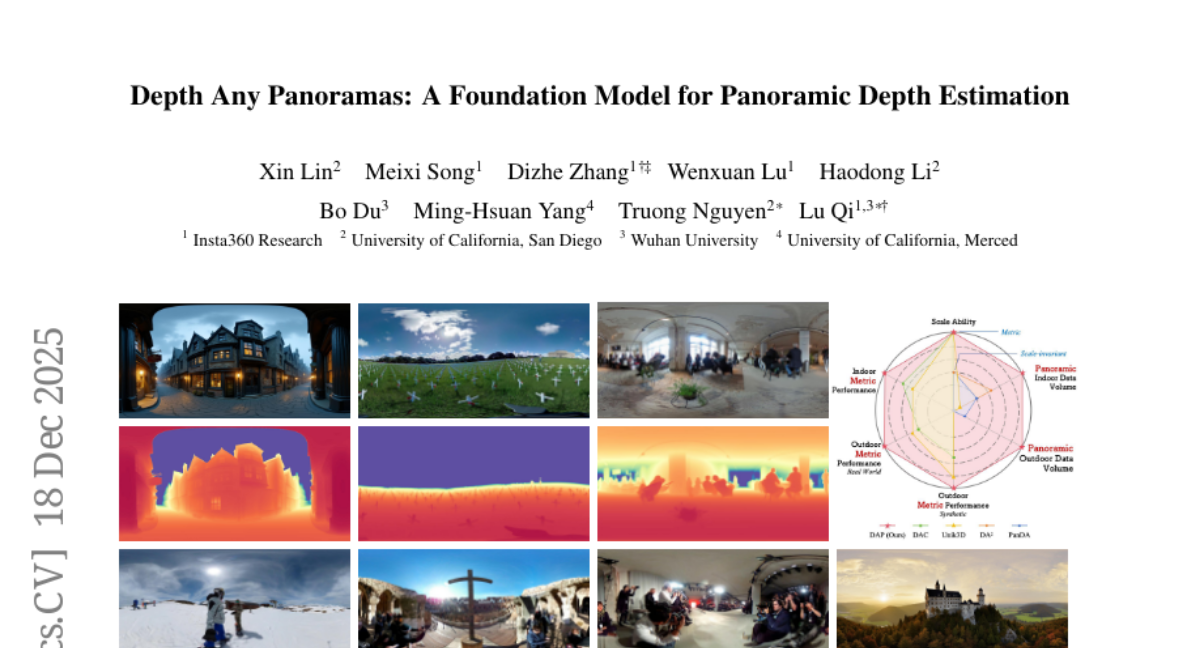
Depth Any Panoramas from Insta360 (Research Team): panoramic-depth-estimation and metric-depth-estimation; Verified.
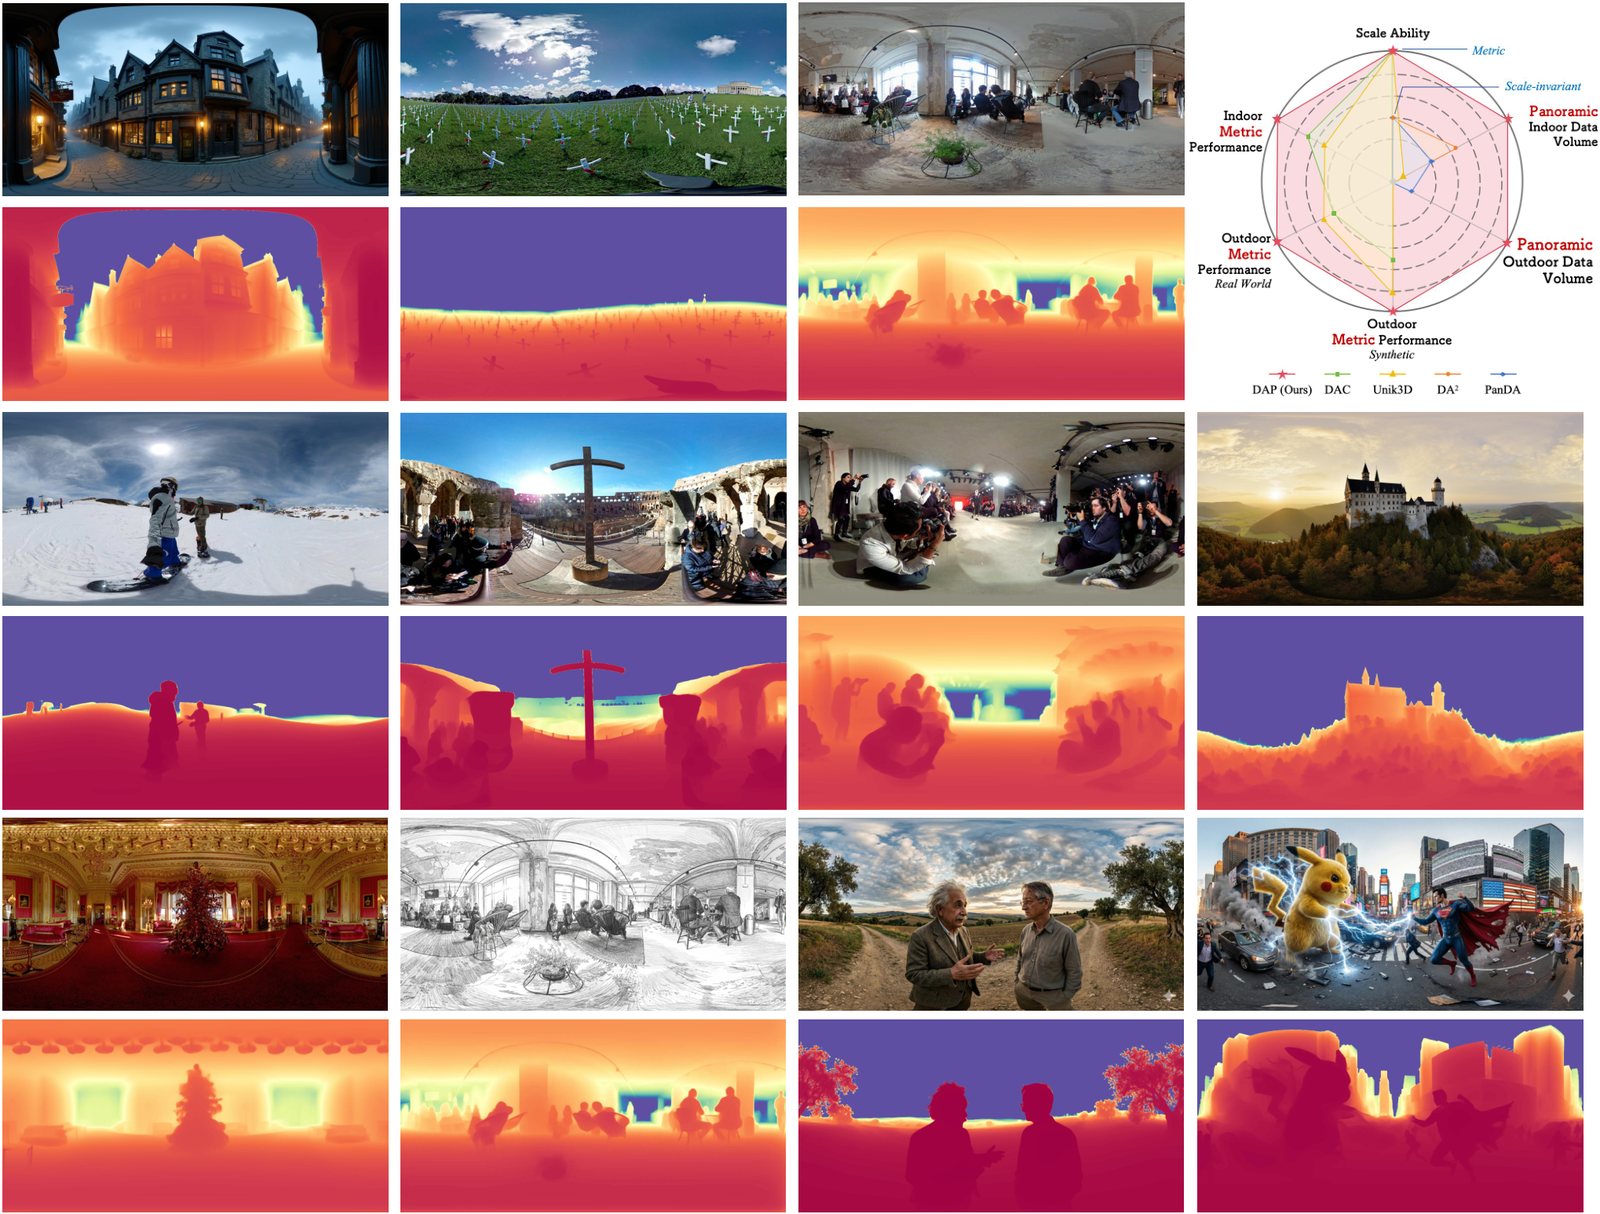
Depth Any Panoramas (DAP) is Insta360's metric depth estimator for panoramic images — full 360° depth from a single equirectangular input. In this catalog it is a verified geometry prior: runner parity passed through the shared geometry-prior contract, with weights at Insta360-Research/DAP-weights.
The recorded paper is arXiv 2512.16913.
Project page: insta360-research-team.github.io/DAP_website. Code: Insta360-Research-Team/DAP.
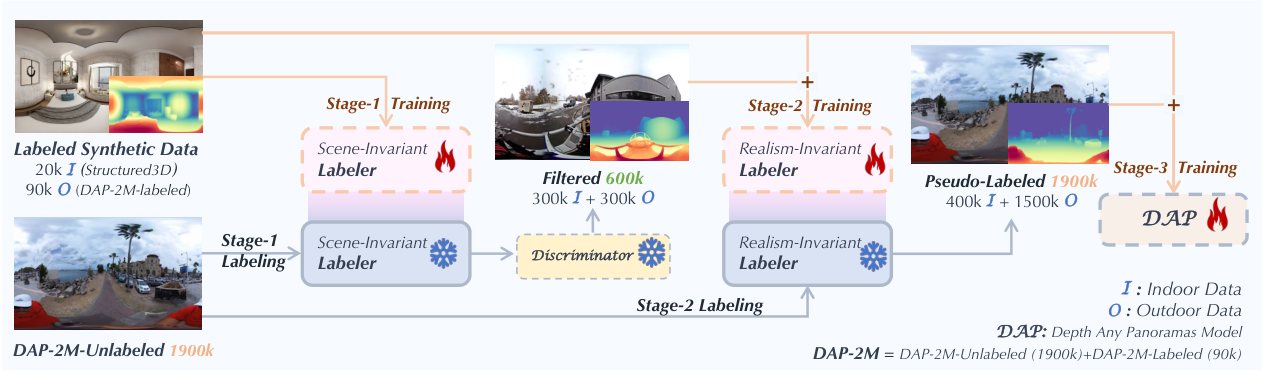
The backbone is DINOv3-Large with a DPT-style decoder. A dense metric depth head is paired with a plug-and-play range-mask head that marks pixels beyond a confident distance (the cards discuss thresholds such as 10 / 20 / 50 / 100 m). Zero-shot numbers in the paper are reported on Stanford2D3D, Matterport3D, and Deep360 — upstream, not a WorldFoundry scorecard.
Build your run
DAPPipelineworldfoundry.pipelines.geometry_priors.pipeline_geometry_priorsdefaultworldfoundry.pipelineworldfoundry-eval run \
dap \
--pipeline.task-profile default \
--jsonWhat it is for
Pick dap for feed-forward geometry: views in, reconstruction / trajectory / point cloud out. Use it when you need the catalog 3D route rather than a depth-only prior.
A Depth-Anything-family backbone adapted to panoramic inputs and metric output. It lives under base_models/three_dimensions/depth as an independent prior; ViPE imports it from this canonical owner. Details beyond the recorded structure are not stored here. It is published by Insta360 (Research Team).
Catalog tasks include panoramic-depth-estimation, metric-depth-estimation, and geometry-prior. Catalog aliases include depth-any-panoramas and insta360-dap. Documented modalities: image in, depth out.
Feed one equirectangular image, get dap-depth.npz. Aliases depth-any-panoramas and insta360-dap resolve here. Higher-level pipelines such as ViPE are supposed to import this canonical owner, not keep a private copy. For ordinary pinhole photos use the Depth Anything V2/V3 priors instead.
Runtime contract
Optional input_path, input_size, execute, max_points, and focal_length; artifacts dap-depth.npz.
CLI task profiles: default. WorldFoundry binds DAPPipeline.
Family status: Verified.
It is integrated as an independent geometry prior under worldfoundry/base_models and exposed through the shared geometry-prior pipeline/operator contract. Higher-level pipelines (e.g. ViPE) import it from this canonical owner instead of keeping private copies.
Integrated as an independent geometric prior at worldfoundry/base_models/three_dimensions/depth/depth_anything/depth_anything_v1.
Running in WorldFoundry
The catalog launch is worldfoundry-eval run dap --pipeline.task-profile default. The command builder above switches --pipeline.task-profile among recorded tasks and still emits worldfoundry-eval run.
It runs in the unified environment worldfoundry-unified-cu128 (Python 3.11, CUDA 12.8).
Recorded weight repositories include Insta360-Research/DAP-weights. Prepare the environment and check local assets with bash scripts/inference/prepare_model_infer.sh dap. Add --download to fetch missing public checkpoints.
Status: Verified.

