MolmoSpaces-Bench
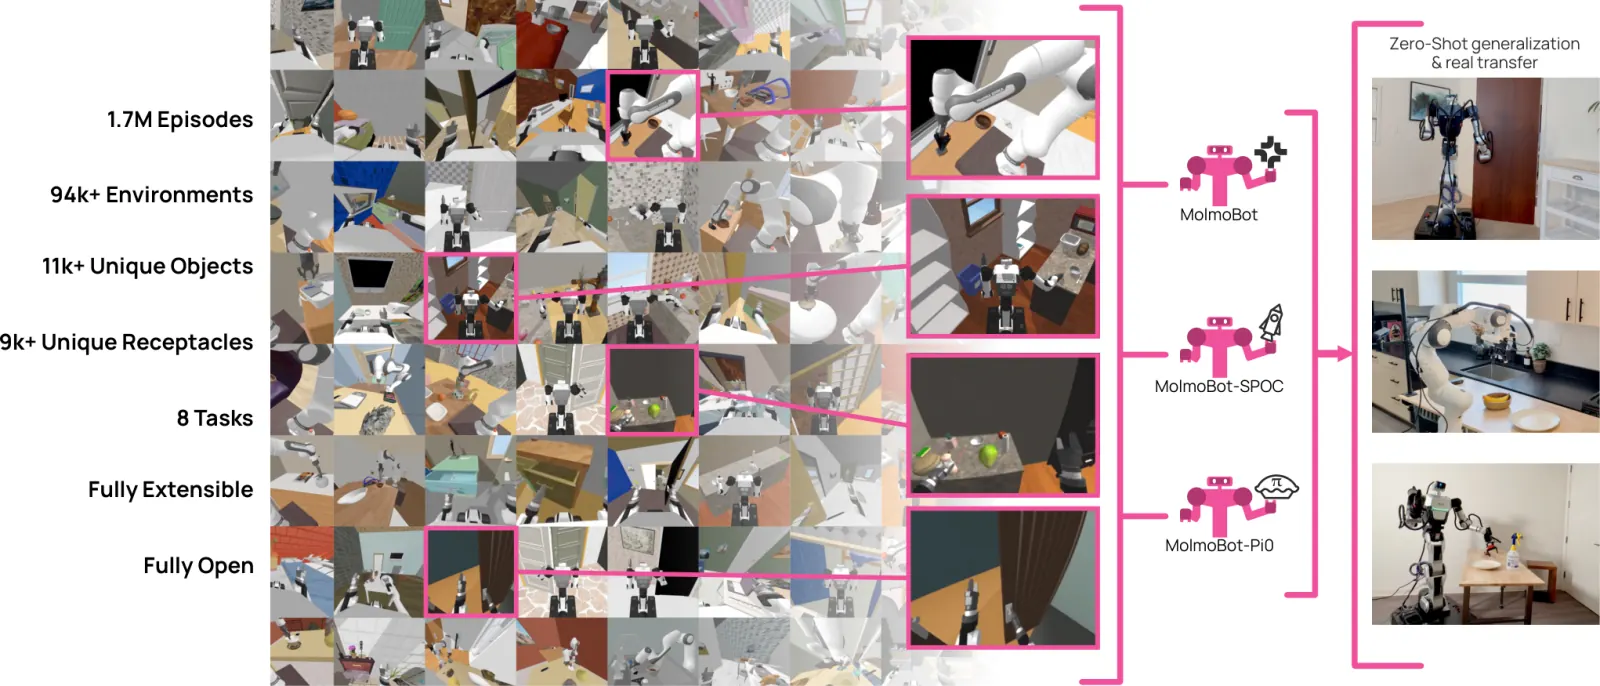
MolmoSpaces-Bench is Allen Institute for AI's simulation eval for MolmoBot / MolmoSpaces spatial-language manipulation. The paper's training dump (MolmoBot-Data) is 1.7 million expert trajectories in an ecosystem cited as 232k environments and 48k manipulable objects — that is not the bench. The bench is a 1,000-episode ladder: Pick MSProc / Classic / photorealistic Pick / Pick Random-Cam (20 s), then Pick&Place, PnP Next-To (5 cm), PnP Color (40 s). Official tables split pick-stage success from final / oracle success. A public board lives at molmospaces.allen.ai/leaderboard; this hub has not ingested its rows.
Paper: MolmoBot. Project: allenai.github.io/MolmoBot. Code: allenai/MolmoBot. WorldFoundry's contract split name is pick_and_place.
WorldFoundry imports official rollout exports. It does not run MolmoSpaces, generate the 1.7M set, or copy the Ai2 board into this page.
Dimensions
- Pick variantsKindTask
Pick MSProc, Pick Classic, photorealistic Pick, and Pick Random-Cam. Official sim episodes are 1,000-long; pick budget is 20 seconds.
- Pick-and-place variantsKindTask
Pick&Place (into a receptacle), PnP Next-To (within 5 cm), PnP Color. 40-second budget. WorldFoundry's contract split name is pick_and_place.
- Pick-stage vs final successKindAxis
Official tables report pick-stage success separately from full-task / oracle final success.
Data composition
- Size
Ai2 eval suite for MolmoBot / MolmoSpaces. Training data (MolmoBot-Data) is 1.7 million expert trajectories in an ecosystem the paper cites as 232k environments and 48k manipulable objects. The bench itself is the 1,000-episode simulation ladder plus a real-robot tabletop protocol — not the 1.7M set. Official board: molmospaces.allen.ai/leaderboard.
- Sources
github.com
- Splits
pick_and_place
- Modalities
language · vision · action · state
- License
upstream_terms
- Notes
An official leaderboard exists. This hub has not ingested its rows. WorldFoundry only normalizes a caller-provided export.
Metrics
Metric
- DirectionHigher is better
success_rateFull-task / final episode success on the imported split.
PrimarySuccess Rate
- DirectionHigher is better
pick_success_ratePick-stage success, reported separately from place / final success.
- DirectionHigher is better
task_successPer-task success aggregate (Pick vs Pick&Place variants).
- DirectionHigher is better
rewardMean episode reward / return when the export includes it.
Leaderboard
Official live board, embedded on this page. Not WorldFoundry-run scores. molmospaces.allen.ai.
How to run
worldfoundry-eval zoo benchmark-run \
  --benchmark-id molmospaces \
  --mode official-validation \
  --official-results-path <official_results.json> \
  --output-dir tmp/molmospaces/official-validation \
  --json
Optional WORLDFOUNDRY_MOLMOSPACES_ROOT points at a local runtime/repo. Default import path: WORLDFOUNDRY_MOLMOSPACES_RESULTS_PATH. Manifest: worldfoundry/data/benchmarks/tasks/external/molmospaces.yaml. Outputs: scorecard.json (primary success_rate; also pick_success_rate), raw_results.jsonl, evaluation/summary.json.