
RoboCasa
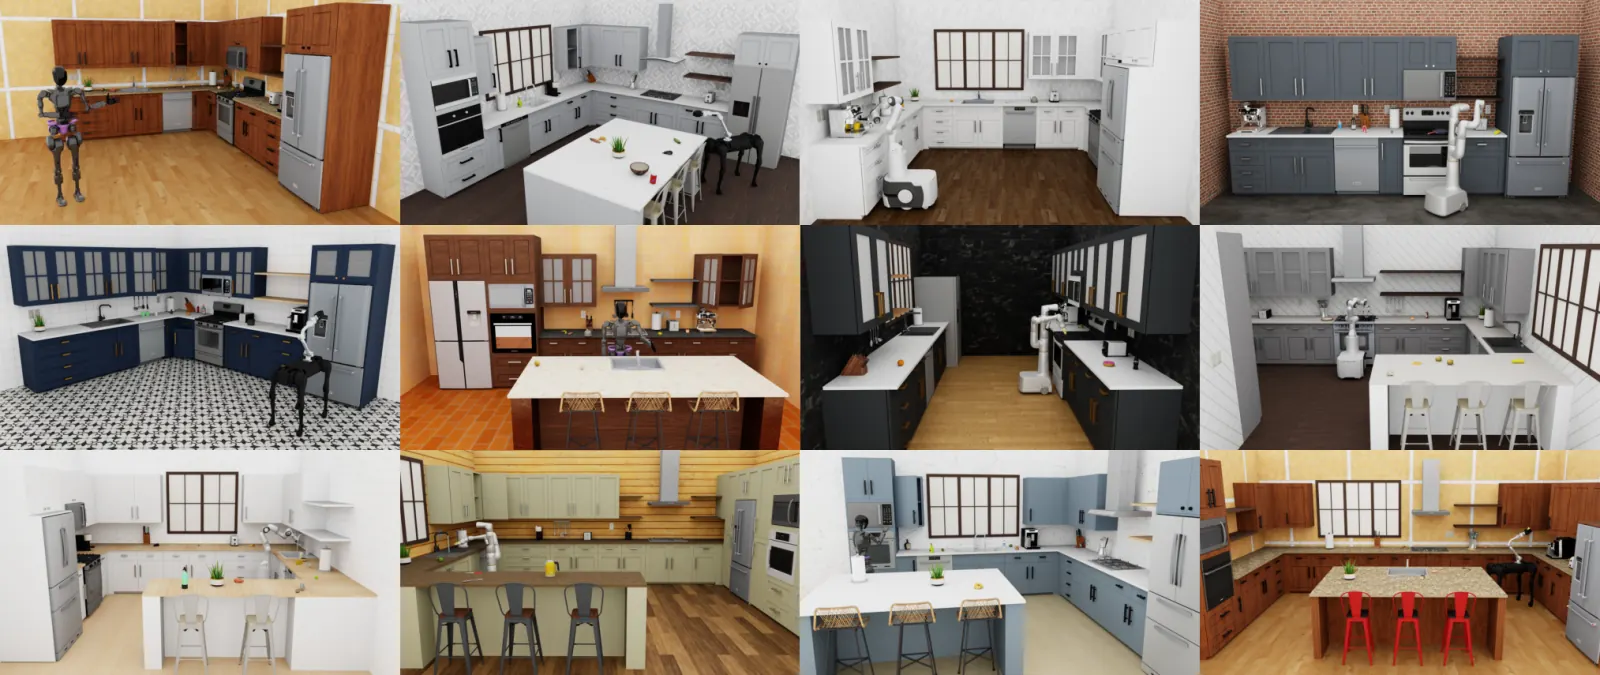
RoboCasa is UT Austin and NVIDIA's large-scale kitchen simulation for generalist robots: 120 realistic kitchen layouts, 2,500+ 3D assets (many generated), and about 100 atomic skills plus composite long-horizon activities, with large demonstration sets. The paper is RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots. Project: robocasa.ai. Code: robocasa/robocasa. GitHub license metadata in this catalog is other:noassertion_github_api — read the upstream terms before reuse.
WorldFoundry imports official rollout exports. Scene assets and long-horizon policy execution stay upstream. Repo mirror: cache/vla_va_wam/repos/robocasa--robocasa. Models such as Being-H0.5 publish a RoboCasa specialist line; that is not a score on this page.
Dimensions
- Atomic kitchen skillsKindSuite
About 100 atomic manipulation skills in kitchen scenes.
- Composite long-horizonKindSuite
Composite tasks that chain atomic skills into longer kitchen activities.
- Kitchen scenesKindAxis
120 realistic kitchen layouts and 2,500+ 3D assets (many generative).
Data composition
- Size
UT Austin & NVIDIA kitchen simulation: 120 scenes, 2,500+ assets, 100 atomic plus composite long-horizon tasks, with large demonstration sets for generalist policies.
- Sources
github.com
- Splits
kitchen · long_horizon
- Modalities
language · vision · action · state
- License
other:noassertion_github_api
- Notes
RoboCasa uses simulator assets and generated policy rollouts rather than a single public HF benchmark table.
Metrics
Metric
- DirectionHigher is better
success_ratePrimary episode success rate over evaluated rollouts.
PrimarySuccess Rate
- DirectionHigher is better
task_successPer-task success aggregate.
- DirectionHigher is better
episode_successPer-episode success indicator aggregate.
- DirectionHigher is better
rewardMean episode reward / return.
Leaderboard
Results from the paper (not a live board; not WorldFoundry-run scores). Same BC policy trained on different data mixes from the paper. RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots (2024).
| Model | Average success (24 atomic tasks) |
|---|---|
| Generated-3000 | 0.476 |
| Generated-300 | 0.350 |
| Human-50 | 0.288 |
| Generated-100 | 0.263 |
How to run
worldfoundry-eval zoo benchmark-run \
  --benchmark-id robocasa \
  --mode official-validation \
  --official-results-path <official_results.json> \
  --output-dir tmp/robocasa/official-validation \
  --json
Default import path: WORLDFOUNDRY_ROBOCASA_RESULTS_PATH. Manifest: worldfoundry/data/benchmarks/tasks/external/robocasa.yaml. Declare atomic vs composite (and the scene split) with the export. Outputs: scorecard.json (primary success_rate) and raw_results.jsonl.