Being-H0.5
BeingBeyond's 2B cross-embodiment VLA: RGB, language, and state in; get_action out. The LIBERO specialist is the GPU-validated WorldFoundry route.
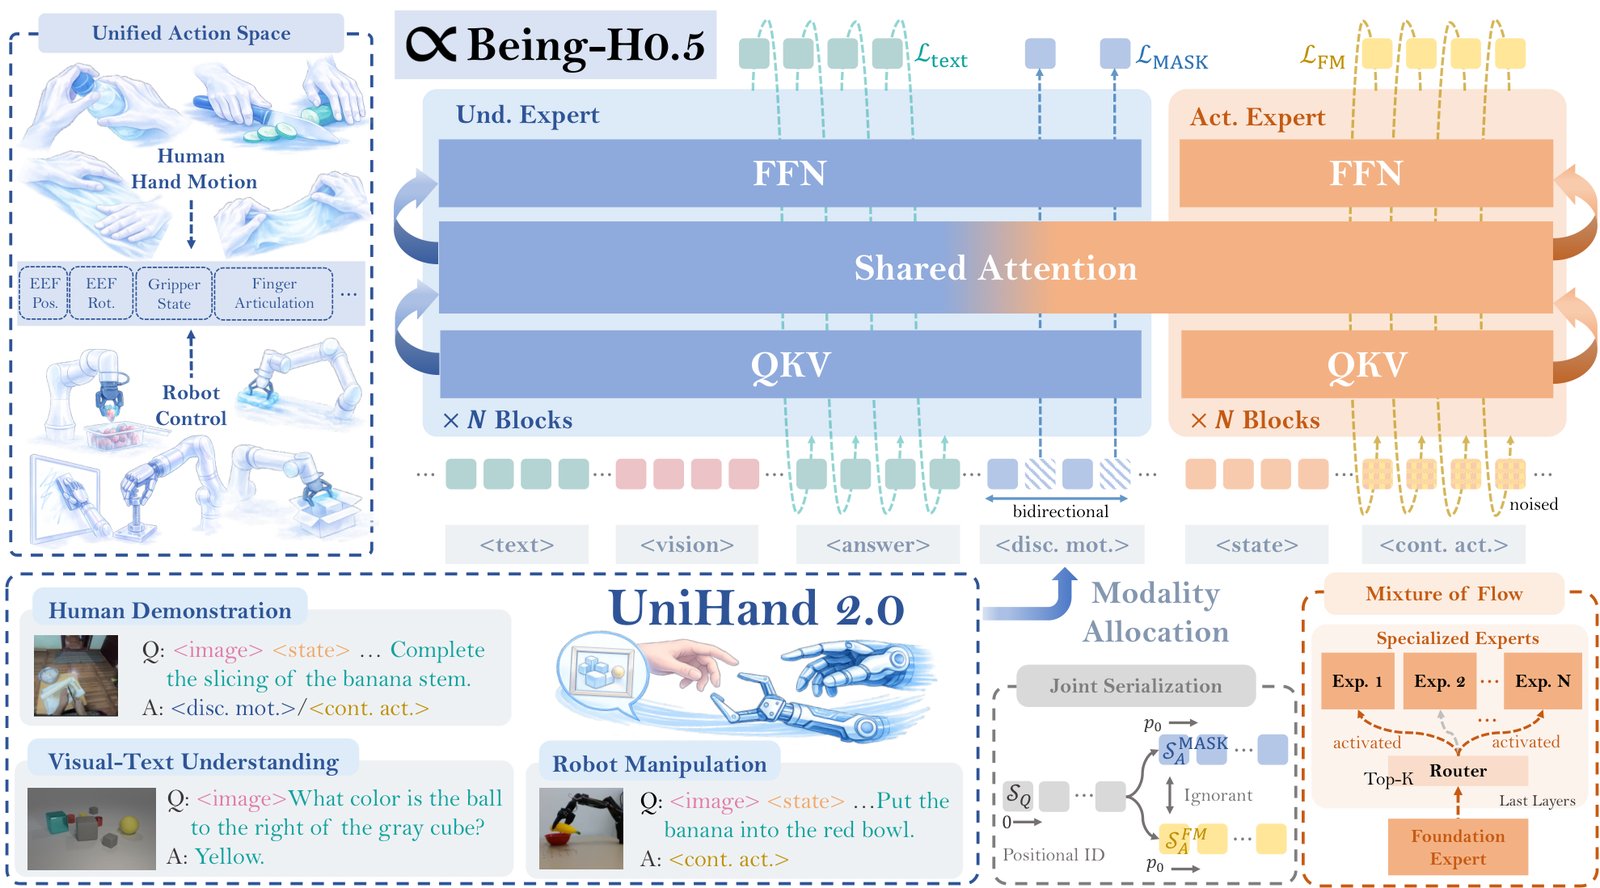
Being-H0.5 is BeingBeyond's 2B-parameter Vision-Language-Action policy for cross-embodiment control. At run time it maps RGB, a language instruction, and robot state into a 200-dimensional unified action space (end-effector, joints, gripper or fingers, base) so one checkpoint can speak different robot control languages instead of shipping a pile of per-robot heads.
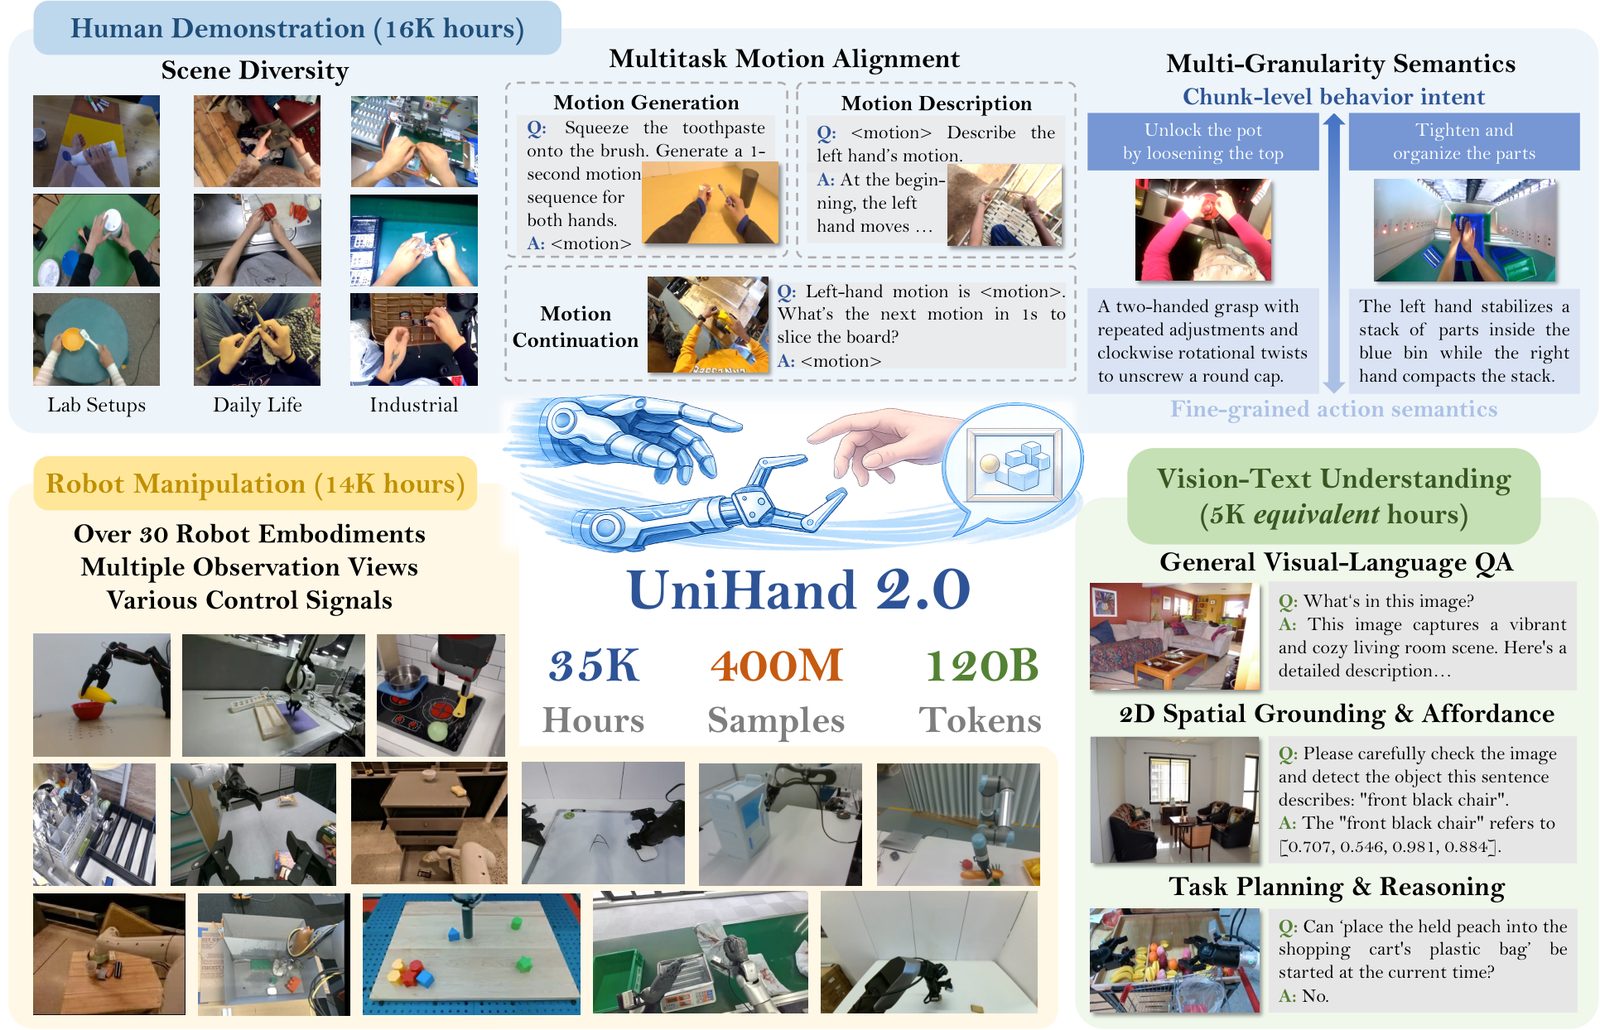
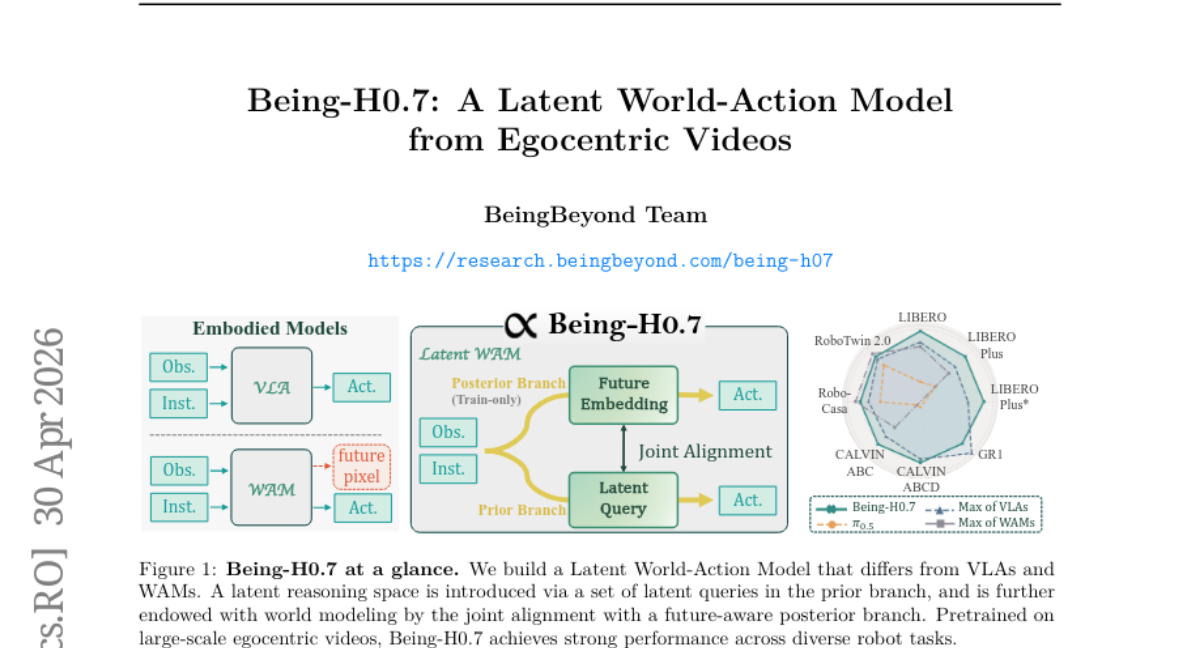
The official paper is Being-H0.5: Scaling Human-Centric Robot Learning for Cross-Embodiment Generalization (arXiv 2601.12993). The project write-up is on BeingBeyond Research. The catalog still lists a later Being-H0.7 arXiv id as the paper URL; that is a different model.
WorldFoundry keeps an inference-only runtime under worldfoundry/synthesis/action_generation/being_h05. Four Hugging Face lines are recorded: base, LIBERO specialist, RoboCasa specialist, and a LIBERO+RoboCasa generalist. Only the LIBERO specialist has a checkpoint-backed GPU get_action validation and an action_trace artifact in this repository.
Build your run
BeingH05Pipelineworldfoundry.pipelines.component_pipelinesinteractive-videoworldfoundry.evaluation.models.runners.pipeline:WorldFoundryPipelineRunnerworldfoundry-eval run \
being-h05-2b \
--pipeline.task-profile interactive-video \
--jsonVariants
- StatusRunner parity pending
being-h05-2bvla.policy_rollout
Runtime profile
being-h05Pipeline binding
being-h05 - StatusRunner parity pending
being-h05-2b-liberovla.policy_rollout
Runtime profile
being-h05Pipeline binding
being-h05 - StatusRunner parity pending
being-h05-2b-robocasavla.policy_rollout
Runtime profile
being-h05Pipeline binding
being-h05 - StatusRunner parity pending
being-h05-2b-libero-robocasavla.policy_rollout
Runtime profile
being-h05Pipeline binding
being-h05
What it is for
Start on being-h05-2b-libero. That is the line WorldFoundry actually ran: multi-view RGB, language instruction, and robot state in; being_h05_action_trace.json out, on an 80 GB GPU with memory-efficient SDPA. Official BeingHPolicy also emits robot-specific actions plus action_unified when RTC is enabled. Default profile pins data_config_name=libero_nonorm, dataset_name=libero_posttrain, embodiment_tag=libero, and $WORLDFOUNDRY_HFD_ROOT/BeingBeyond--Being-H05-2B_libero. Paper evaluation on this 2B backbone uses RGB-only 224×224.
Use being-h05-2b-robocasa when the kitchen suite is the target. The combined being-h05-2b-libero-robocasa checkpoint loaded on GPU in a tensor probe, but a real get_action exceeded a single 80 GB card — do not treat that variant as a validated rollout path here.
The base being-h05-2b card is the unspecialized preview, not a suite specialist. For simulated suites that match the released specialists, the natural next pages are LIBERO and RoboCasa.
Runtime contract
Required WorldFoundry inputs: image, instruction, prompt, and state. Optional: video. The actions field is recorded as robot_action, action_unified, proprio, action_space. Pipeline class: BeingH05Pipeline. Launch worldfoundry-eval run being-h05-2b — pick the LIBERO variant unless you are comparing checkpoints.
Two inference-time pieces travel with the released checkpoint. Manifold-Preserving Gating drops unreliable context under sensory shift so flow updates stay on a stable action manifold. Universal Async Chunking keeps action chunks consistent across different control rates and delays.
The paper reports 98.9% LIBERO success in the specialist setting and 97.6% in the generalist setting, and 53.9% / 53.3% on RoboCasa Human-50. Those are upstream numbers, not a WorldFoundry scorecard. Real-robot results in the paper cover five embodiments and ten tasks (spatial, long-horizon, bimanual, generalization); this catalog does not claim those rollouts.
Running in WorldFoundry
Use the dedicated environment worldfoundry-being-h05 (Python 3.10, CUDA 11.8 or newer). Weights must already be staged — the runtime does not download them. Safetensors are preferred; legacy .bin / .pt load with strict key matching.
The GitHub tree is Apache-2.0. Every recorded Hugging Face repo is tagged manual_review:missing_hf_license — confirm the card before any production use.
Minimal eval
being-h05-2b-libero is the GPU-validated get_action line. An action trace is not a suite score. Import official LIBERO eval_result trees with worldfoundry-eval zoo benchmark-run --benchmark-id libero --mode official-validation and read success_rate. Closed-loop is wired; this repo has not recorded a Being-H0.5 leaderboard.