Metric3D
Metric3D from DJI / Zhejiang University: monocular-depth-estimation and metric-depth-estimation; Verified.
Metric3D recovers metric-scale depth from a single image by normalizing images into a canonical camera space, which lets one model generalize across cameras. In this catalog it is a verified metric-depth prior: the VIPE SLAM defaults reference it by name through the shared priors factory, and checkpoint-backed inference runs through the geometry-prior contract.
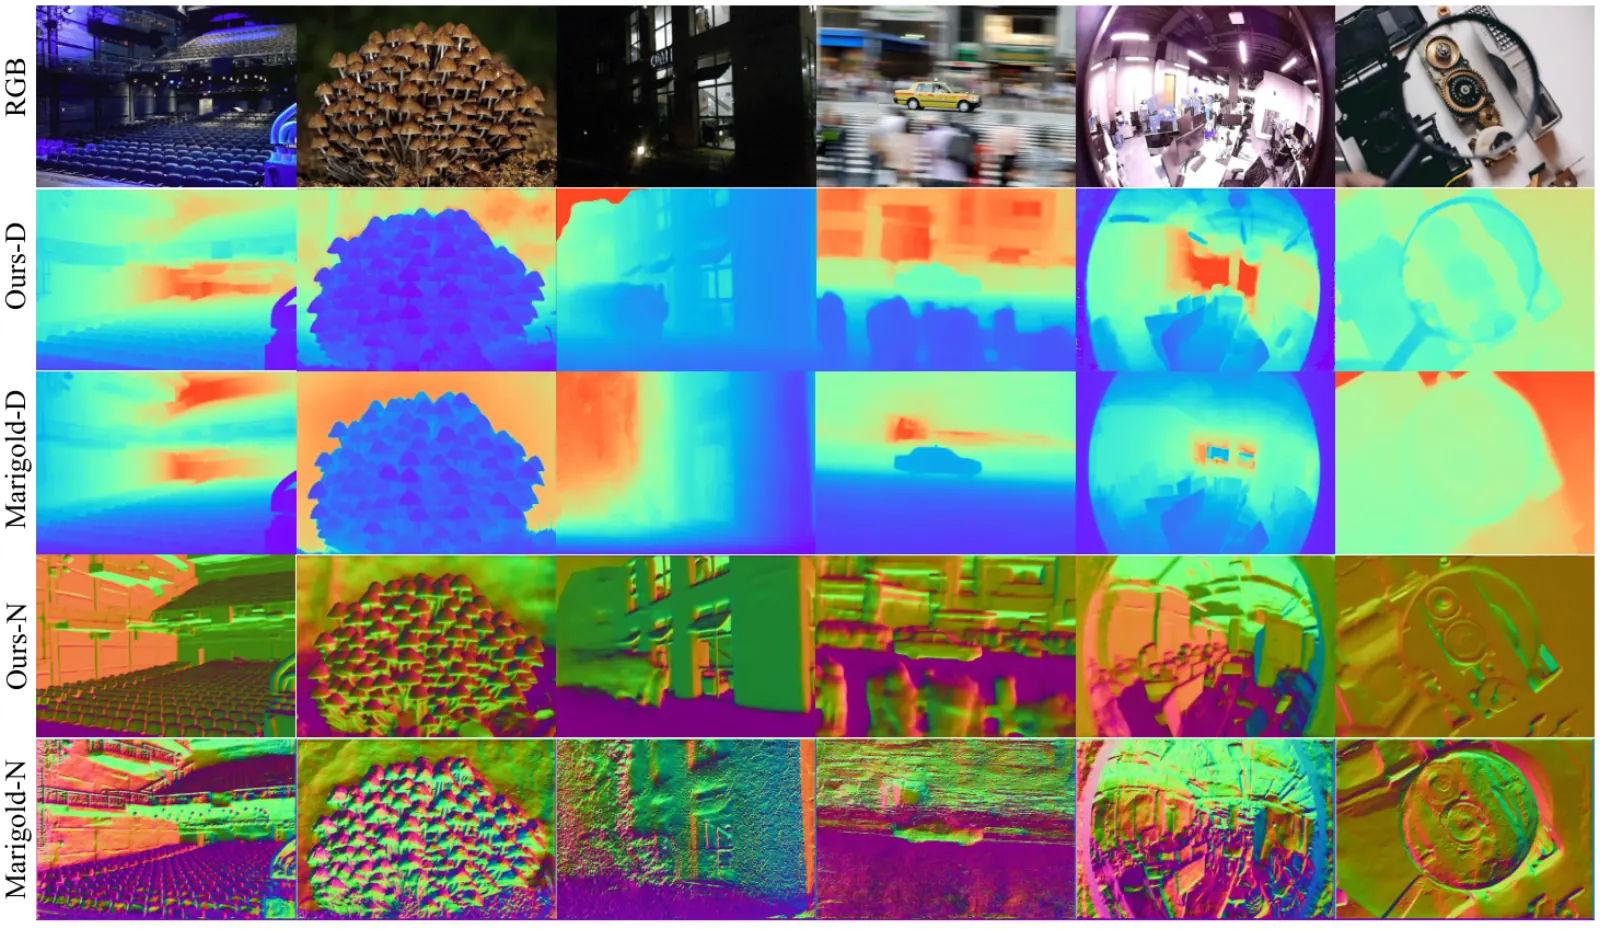
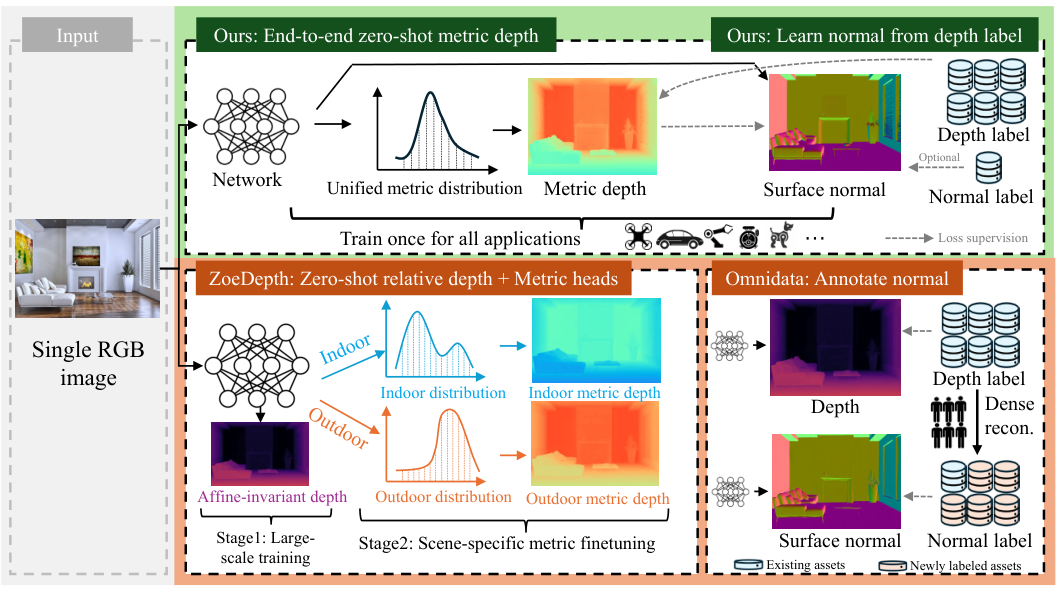
The recorded paper is arXiv 2403.12013.
Project page: jugghm.github.io/Metric3Dv2. Code: YvanYin/Metric3D.
Build your run
Metric3DPriorPipelineworldfoundry.pipelines.geometry_priors.pipeline_geometry_priorsdefaultworldfoundry.pipelineworldfoundry-eval run \
metric3d-prior \
--pipeline.task-profile default \
--jsonWhat it is for
metric3d-prior is the recorded reconstruction line. Start here to emit geometry from the documented views.
Per the upstream publication (ICCV 2023), a canonical-camera transformation resolves the metric ambiguity of single-image depth, and the recorded checkpoint is JUGGHM/Metric3D under a bsd-2-clause license. Registered at base_models/three_dimensions/depth/metric3d. It is published by DJI / Zhejiang University.
Catalog tasks include monocular-depth-estimation, metric-depth-estimation, and geometry-prior. Catalog aliases include metric3d and yvanyin-metric3d.
Runtime contract
Optional input_path, model, version, focal_length, and execute; artifacts metric3d-prior.npz.
CLI task profiles: default. WorldFoundry binds Metric3DPriorPipeline.
Family status: Verified.
It is integrated as an independent geometry prior under worldfoundry/base_models and exposed through the shared geometry-prior pipeline/operator contract. Higher-level pipelines (e.g. ViPE) import it from this canonical owner instead of keeping private copies. Runner parity is verified through the shared contract; it is the default metric-depth choice in the VIPE SLAM configuration.
Integrated as an independent metric-depth prior at worldfoundry/base_models/three_dimensions/depth/metric3d.
Running in WorldFoundry
Launch worldfoundry-eval run metric3d-prior --pipeline.task-profile default to write geometry. The command builder above switches --pipeline.task-profile among recorded tasks and still emits worldfoundry-eval run.
It runs in the unified environment worldfoundry-unified-cu128 (Python 3.11, CUDA 12.8).
Recorded weight repositories include JUGGHM/Metric3D. Prepare the environment and check local assets with bash scripts/inference/prepare_model_infer.sh metric3d-prior. Add --download to fetch missing public checkpoints.
Status: Verified.