RoboTwin 2.0
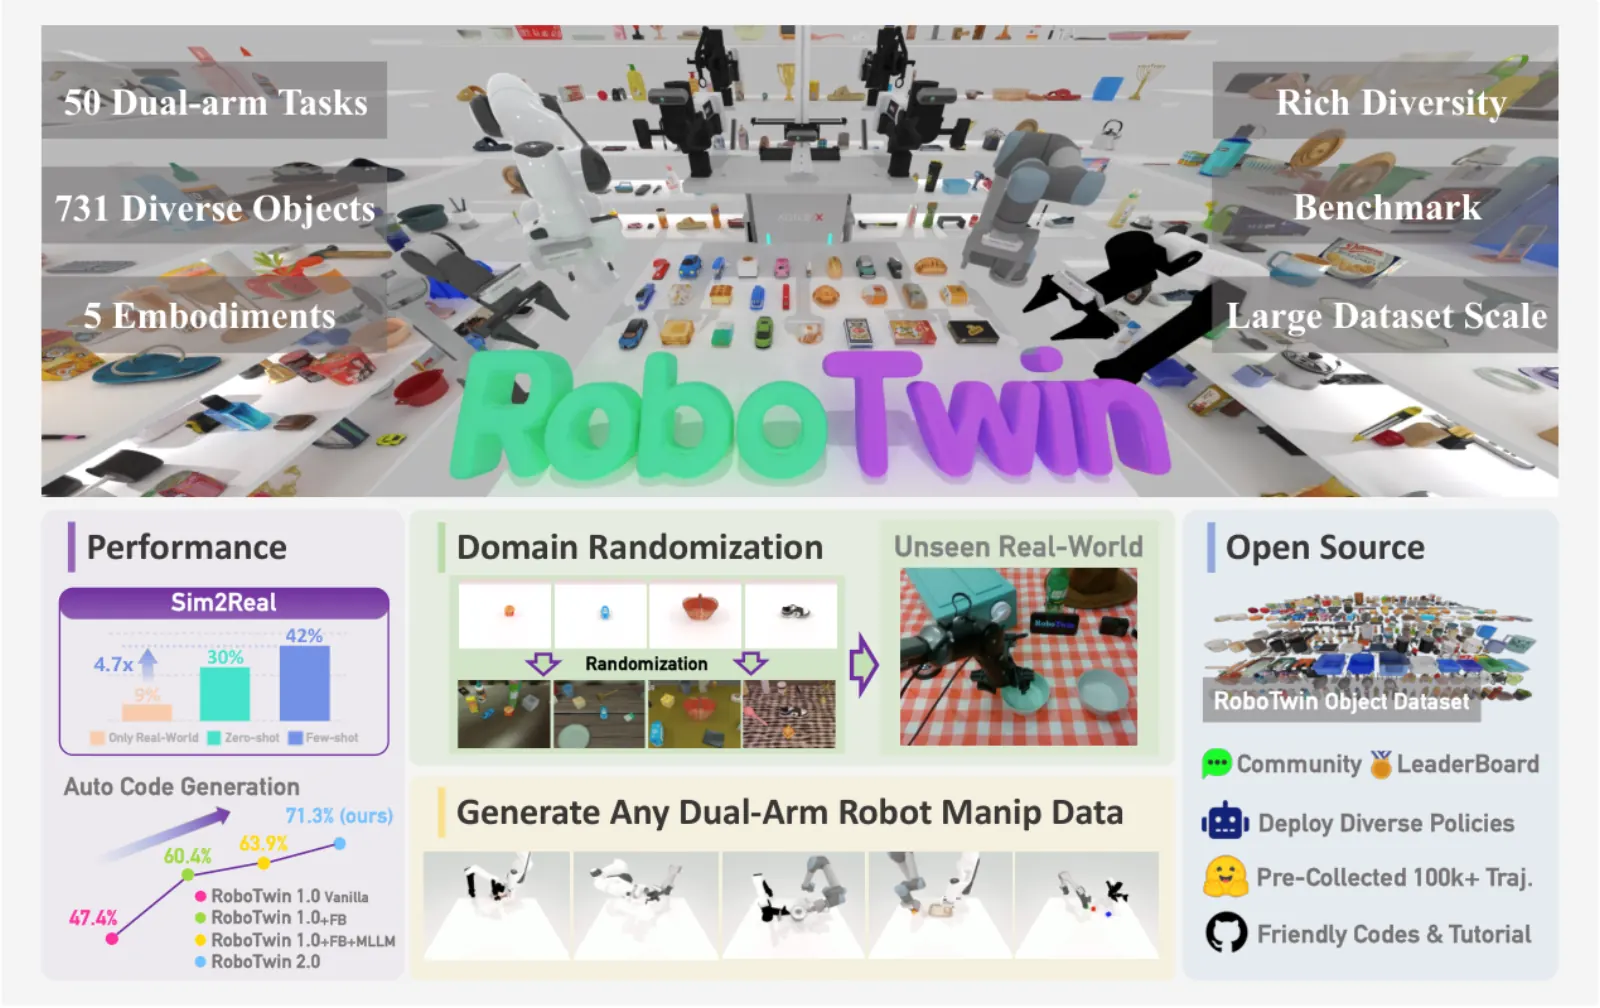
RoboTwin 2.0 (The University of Hong Kong and Shanghai AI Laboratory, with AgileX) is a bimanual SAPIEN benchmark, not a video-generation suite. The paper instantiates 50 dual-arm tasks on RoboTwin-OD (731 objects, 147 categories) across five embodiments: Aloha-AgileX, ARX-X5, Piper, Franka Panda, and UR5-WSG. Domain randomization is five axes — clutter, lighting, background, tabletop height, language — and clean vs randomized success are reported separately. The companion dump is 100k+ expert trajectories (TianxingChen/RoboTwin2.0).
Paper: RoboTwin 2.0. Project: robotwin-platform.github.io. Docs: usage / configurations. Code: RoboTwin-Platform/RoboTwin. Official board: leaderboard — not ingested here.
WorldFoundry imports official eval_result/_result.txt (layout eval_result/{task}/{policy}/{config}/{ckpt}/{timestamp}/_result.txt) or structured JSON/CSV. Offline normalization needs no simulator. Real parity still needs the upstream SAPIEN / Curobo stack and the official policy/*/eval.sh scripts. A 2026-05-25 bounded local check reached CUDA allocation; script/test_render.py hit the timeout, so rendering is not claimed green. Shared stack: robotwin_dataset_assets.
Dimensions
- CleanKindSplit
Non-randomized dual-arm rollouts. Report separately from randomized success.
- Domain-randomizedKindSplit
Official five-axis randomization: clutter, lighting, background, tabletop height, language.
- Five embodimentsKindAxis
Aloha-AgileX, ARX-X5, Piper, Franka Panda, UR5-WSG. Declare the embodiment with the export.
- 50 dual-arm tasksKindSuite
Pick-and-place, stacking, containment, tool use, transport, articulated and deformable handling.
Data composition
- Size
50 dual-arm tasks, RoboTwin-OD (731 objects / 147 categories), five embodiments, 100k+ pre-collected trajectories. Official dumps: TianxingChen/RoboTwin2.0 (MIT) and lerobot/robotwin_unified (license under review).
- Sources
TianxingChen/RoboTwin2.0 · lerobot/robotwin_unified · github.com
- Splits
demo_clean · demo_randomized
- Modalities
language · vision · action · state · proprioception · rgb · depth · pointcloud
- License
mit
- Notes
Official leaderboard lives at robotwin-platform.github.io/leaderboard. WorldFoundry has not ingested those rows.
Metrics
Metric
- DirectionHigher is better
success_ratePrimary episode success imported from official eval_result/_result.txt or a structured export.
PrimarySuccess Rate
- DirectionHigher is better
task_successPer-task success among the 50 dual-arm tasks.
- DirectionHigher is better
episode_successPer-episode success indicator when the export lists individual rollouts.
- DirectionHigher is better
bimanual_task_successSuccess on dual-arm coordination tasks when the export splits them out.
- DirectionHigher is better
domain_randomization_successSuccess under the official five-axis randomized condition.
- DirectionHigher is better
clean_successSuccess on the clean (non-randomized) split.
- DirectionHigher is better
randomized_successSuccess on the clutter / lighting / background / height / language split.
- DirectionHigher is better
rewardMean episode return if the official dump includes it.
Leaderboard
Official live board, embedded on this page. Not WorldFoundry-run scores. robotwin-platform.github.io.
How to run
worldfoundry-eval zoo benchmark-run \
  --benchmark-id robotwin \
  --mode official-validation \
  --official-results-path <official_results.json> \
  --output-dir tmp/robotwin/official-validation \
  --json
--official-results-path may point at a _result.txt tree or a JSON/CSV export. Optional WORLDFOUNDRY_ROBOTWIN_ROOT overrides the runtime/repo root. Default import path: WORLDFOUNDRY_ROBOTWIN_RESULTS_PATH. Manifest: worldfoundry/data/benchmarks/tasks/external/robotwin.yaml.
In-tree pointers:
cache/worldfoundry/data/hfd_datasets/TianxingChen__RoboTwin2.0
cache/worldfoundry/data/hfd_datasets/lerobot__robotwin_unified
cache/vla_va_wam/repos/RoboTwin-Platform--RoboTwin
Outputs: scorecard.json (primary success_rate), benchmark_contract.json, task_manifest.json, official_command_manifest.json, simulator_validation.json, raw_metric_table.jsonl, and evaluation/per_sample_metrics.jsonl.