
SANA-WM 80-Scene Benchmark
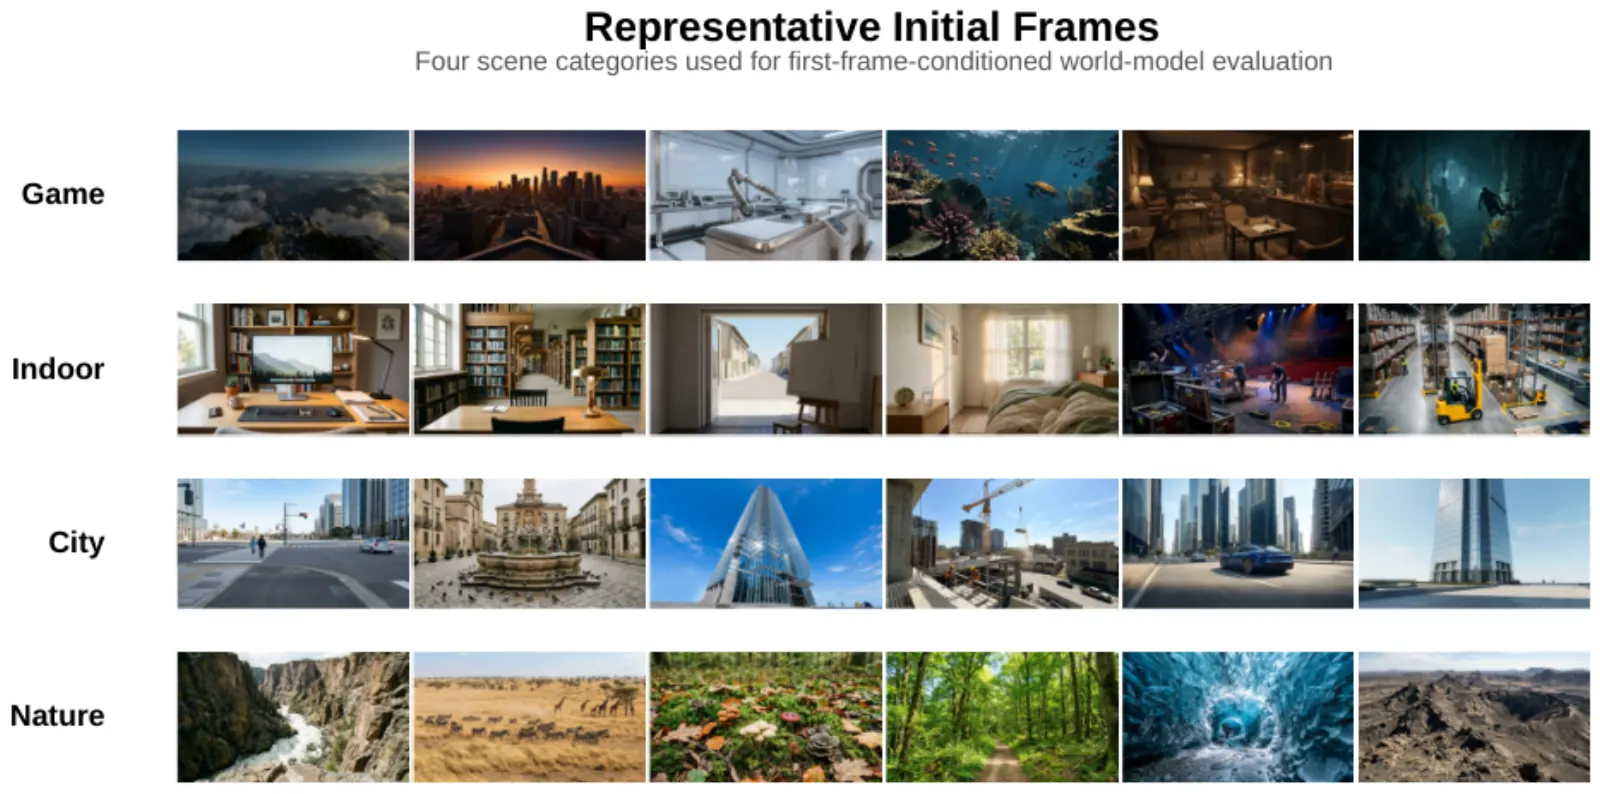
The SANA-WM 80-Scene Benchmark accompanies NVIDIA's SANA world-model work. Each of two splits (simple_60s, hard_60s) holds 80 scenes: a conditioning image plus a 961-frame, 16 FPS camera trajectory. The world model must roll out one minute of video per scene. Four families:
- VBench-style quality — visual / temporal dimensions; primary key
vbench_overall. - Revisit consistency — PSNR / SSIM / LPIPS on frame pairs where the trajectory returns to a prior viewpoint.
- Camera pose — rotation error (degrees), relative translation error, relative motion consistency vs the target trajectory.
delta_iq— imaging-quality drop across temporal windows (long-horizon drift; lower is better).
Code: NVlabs/Sana. Data: Efficient-Large-Model/SANA-WM-Bench (Apache-2.0).
WorldFoundry implements the evaluator in tree. It reuses resident VBench and Pi3 rather than executing an NVlabs/Sana checkout at score time. Pose inference is a separately schedulable GPU stage; only eval_poses.json is consumed.
Dimensions
- KindSplit
simple_60s80 scenes, 961-frame / 16 FPS camera trajectory, one-minute rollout.
- KindSplit
hard_60s80 harder scenes with the same 961-frame / 16 FPS protocol.
Data composition
- Size
NVIDIA SANA-WM 80-scene world-model bench. Two splits × 80 scenes, 961-frame 16 FPS trajectories. Families: VBench quality, revisit consistency, camera pose, delta_iq. Apache-2.0.
- Sources
Efficient-Large-Model/SANA-WM-Bench · github.com
- Splits
simple_60s · hard_60s
- Modalities
text · image · video · camera-trajectory
- License
Apache-2.0
- Notes
WorldFoundry owns the evaluator and reuses resident VBench/Pi3. Full 80×2 numerical parity has not been run. Pose inference is a separate GPU stage.
Metrics
Metric
- DirectionHigher is better
vbench_overallMean over the resident VBench visual/temporal quality dimensions.
PrimaryVBench Overall
- DirectionHigher is better
vbench_total_scoreVBench total_score diagnostic aggregate.
- DirectionHigher is better
revisit_psnrPSNR between frame pairs where the trajectory revisits a previous viewpoint.
- DirectionHigher is better
revisit_ssimSSIM over the same revisit frame pairs.
- DirectionLower is better
revisit_lpipsLPIPS over the same revisit frame pairs.
- DirectionLower is better
rot_err_degCamera rotation error in degrees against the target trajectory.
- DirectionLower is better
trans_err_relRelative camera translation error against the target trajectory.
- DirectionLower is better
cam_mc_relRelative camera motion-consistency error.
- DirectionLower is better
delta_iqImaging-quality degradation across temporal windows (long-horizon drift).
Leaderboard
Results from the paper (not a live board; not WorldFoundry-run scores). Table 2 simple-trajectory split. Resolutions differ (LingBot-World / Infinite-World / HY-WorldPlay at 480p; others 720p). SANA-WM: Efficient Minute-Scale World Modeling with Hybrid Linear Diffusion Transformer (2026).
| Model | VBench Overall (simple-trajectory) |
|---|---|
| LingBot-World480p | 81.82 |
| SANA-WM + refiner | 80.62 |
| SANA-WM | 79.29 |
| Infinite-World480p | 79.18 |
| Matrix-Game 3.0 | 78.53 |
| HY-WorldPlay480p | 68.82 |
How to run
hf download Efficient-Large-Model/SANA-WM-Bench --repo-type dataset \
  --local-dir "${WORLDFOUNDRY_SANA_WM_BENCH_DATASET_ROOT}"

${WORLDFOUNDRY_UNIFIED_PYTHON} \
  worldfoundry/evaluation/tasks/execution/runners/sana_wm_bench/run_sana_wm_bench_official_runner.py \
  --run-official \
  --dataset-root "${WORLDFOUNDRY_SANA_WM_BENCH_DATASET_ROOT}" \
  --generated-video-dir "${WORLDFOUNDRY_GENERATED_ARTIFACT_DIR}" \
  --split simple_60s \
  --metrics vbench,revisit,temporal \
  --output-dir tmp/sana_wm_bench/official \
  --json
Name videos <scene_id>_generated.mp4. --metrics selects vbench,revisit,temporal,camera. --max-pairs bounds revisit pairs; --revisit-lpips adds LPIPS. Camera metrics need --pose-results-path / eval_poses.json (radians converted to degrees on import). Dataset layout: images/<scene_id>.png, <split>/sanawm_export_v2/<scene_id>.npz, run_manifest.jsonl.
In-tree pointer: worldfoundry/data/benchmarks/tasks/external/sana-wm-bench.yaml.
Outputs include scorecard.json (primary vbench_overall) and raw_metric_table.jsonl.