World-in-World
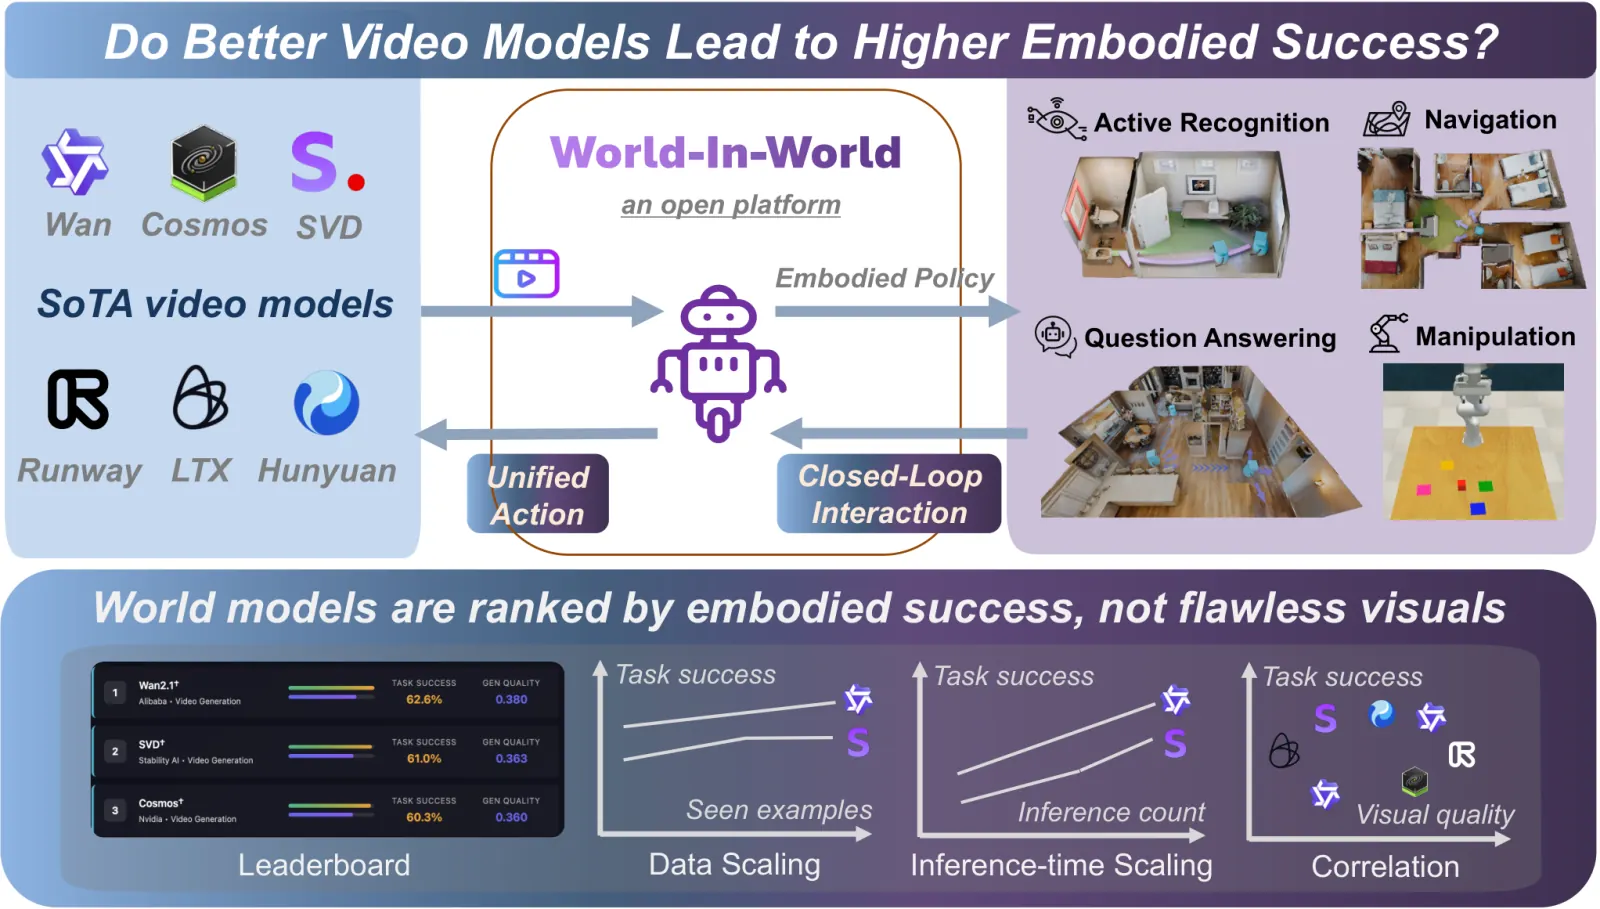
World-in-World(约翰霍普金斯,联合北大、普林斯顿、MIT 与哈佛;ICLR 2026 口头)在镜像智能体-环境交互的 闭环 里评生成式世界模型。任务成功优先于视觉质量。 统一在线规划器与标准化动作 API 覆盖四个环境:
- Active Recognition
- Active Embodied QA
- Image-Goal Navigation(成功率 + SPL)
- 机器人操作
论文发现:视觉质量本身不保证成功(可控性更重要);动作-观察后训练优于升级视频生成器;推理时计算能提升闭环表现。
world_in_world_average 是已有闭环指标的均值。
论文:World-in-World。项目:world-in-world.github.io。代码:World-In-World/world-in-world。
WorldFoundry 是 结果导入器。闭环环境、规划器、worker 与任务打分器在 上游 执行。捆绑资产只支持解析与覆盖检查。
评测维度
- 主动识别类型任务
闭环识别成功。
- 主动具身问答类型任务
答题分加探索 SPL。
- 图像目标导航类型任务
成功率与 SPL。
- 机器人操作类型任务
闭环操作成功。
数据组成
- 规模
ICLR 2026 口头闭环效用评测。四个环境,统一规划器与动作 API。任务成功优先于视觉质量。
- 来源
github.com
- 模态
video · action · observation
- 说明
WorldFoundry 只导入任务摘要。闭环 runtime 对齐仍待完成。
指标
指标
- 方向越高越好
active_recognition_success_rate主动识别闭环任务成功率。
- 方向越高越好
image_goal_navigation_success_rate图像目标导航成功率。
- 方向越高越好
image_goal_navigation_spl图像目标导航按路径长度加权的成功率(SPL)。
- 方向越高越好
active_embodied_qa_score主动具身 QA 的答案得分。
- 方向越高越好
active_embodied_qa_spl主动具身 QA 探索过程的 SPL。
- 方向越高越好
robotic_manipulation_success_rate机器人操作任务成功率。
- 方向越高越好
interaction_trace_consistency世界模型预测交互轨迹的一致性。
- 方向越高越好
world_in_world_average可用闭环任务指标的均值。
主指标World In World Average
Leaderboard
论文报告结果(非实时榜;不是 WorldFoundry 跑分)。 论文主动识别成功率。† 表示视频生成后训练。 World-in-World: World Models in a Closed-Loop World (2025).
| 模型 | 主动识别成功率 |
|---|---|
| WAN2.1 †post-train | 62.98 |
| SVD †post-train | 60.62 |
| Wan2.1 | 58.26 |
| SVD | 57.71 |
| Hunyuan | 57.71 |
| SE3DS | 57.53 |
| Heuristic (w/o WM) | 39.02 |
如何运行
worldfoundry-eval zoo benchmark-run \
  --benchmark-id world-in-world \
  --mode official-validation \
  --official-results-path <official_results.json> \
  --generated-artifact-dir <generated_videos> \
  --output-dir tmp/world-in-world/official-validation \
  --json
可选 --task / --exp-id 限定导入范围。默认:WORLDFOUNDRY_WORLD_IN_WORLD_RESULTS_PATH。
仓内指针:worldfoundry/data/benchmarks/tasks/external/world-in-world.yaml,worldfoundry/data/benchmarks/assets/world-in-world,worldfoundry/evaluation/tasks/execution/runners/world_in_world。
产物包括 scorecard.json(主键 world_in_world_average)。