OpenVLA
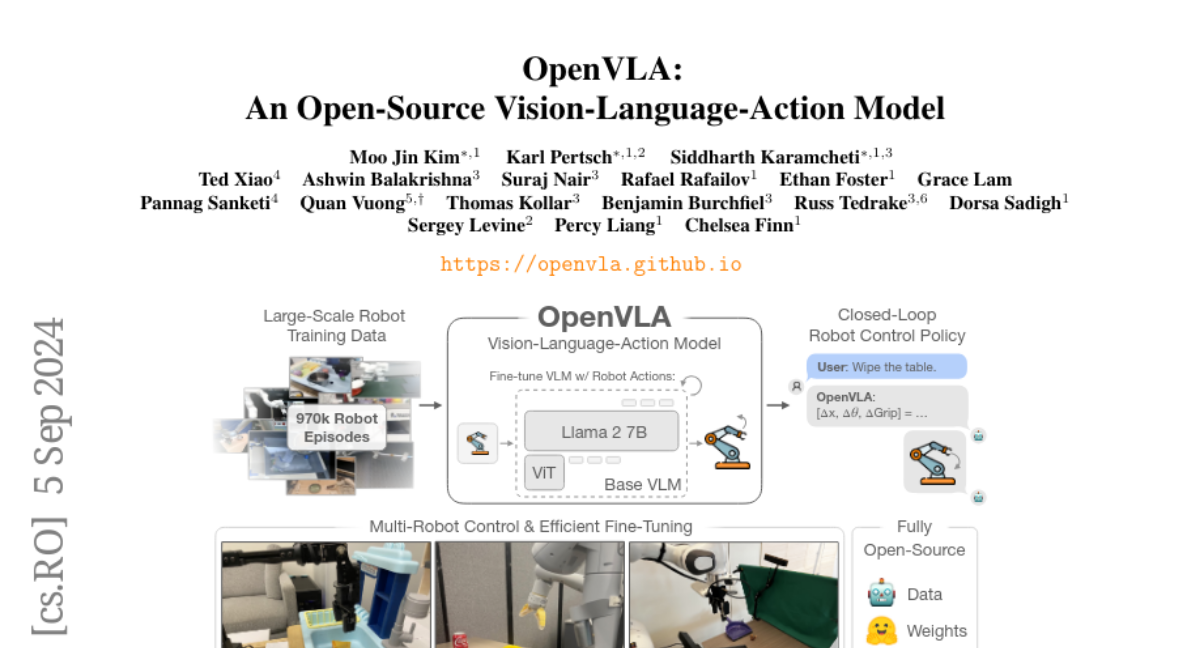
Open 7B VLA: Prismatic VLM emits 7-DoF action tokens; WorldFoundry verifies the base route with unnorm_key=bridge_orig.
OpenVLA is a 7B vision-language-action policy: a Prismatic VLM that turns one RGB frame and a language instruction into discretized action tokens, then de-tokenizes them into continuous 7-DoF controls. The official paper is OpenVLA: An Open-Source Vision-Language-Action Model (arXiv 2406.09246). The project page is openvla.github.io. The GitHub tree is openvla/openvla. Weights are MIT.
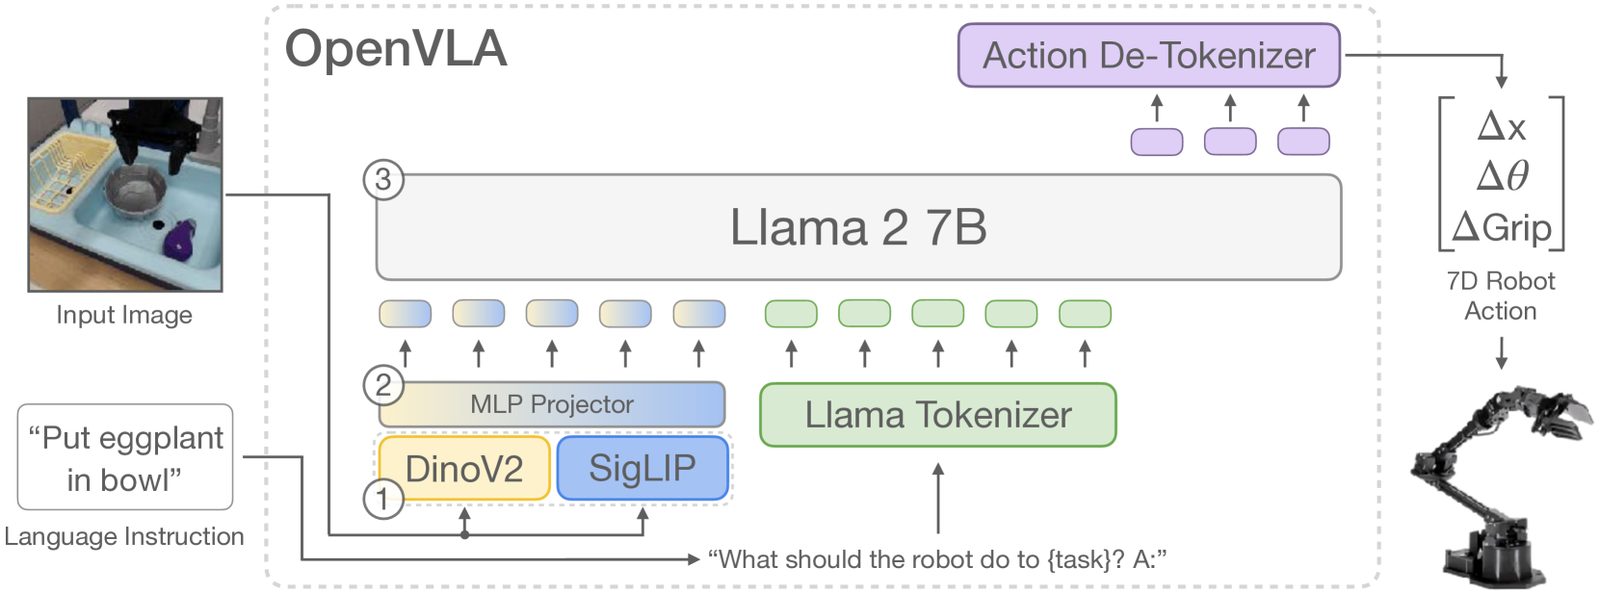
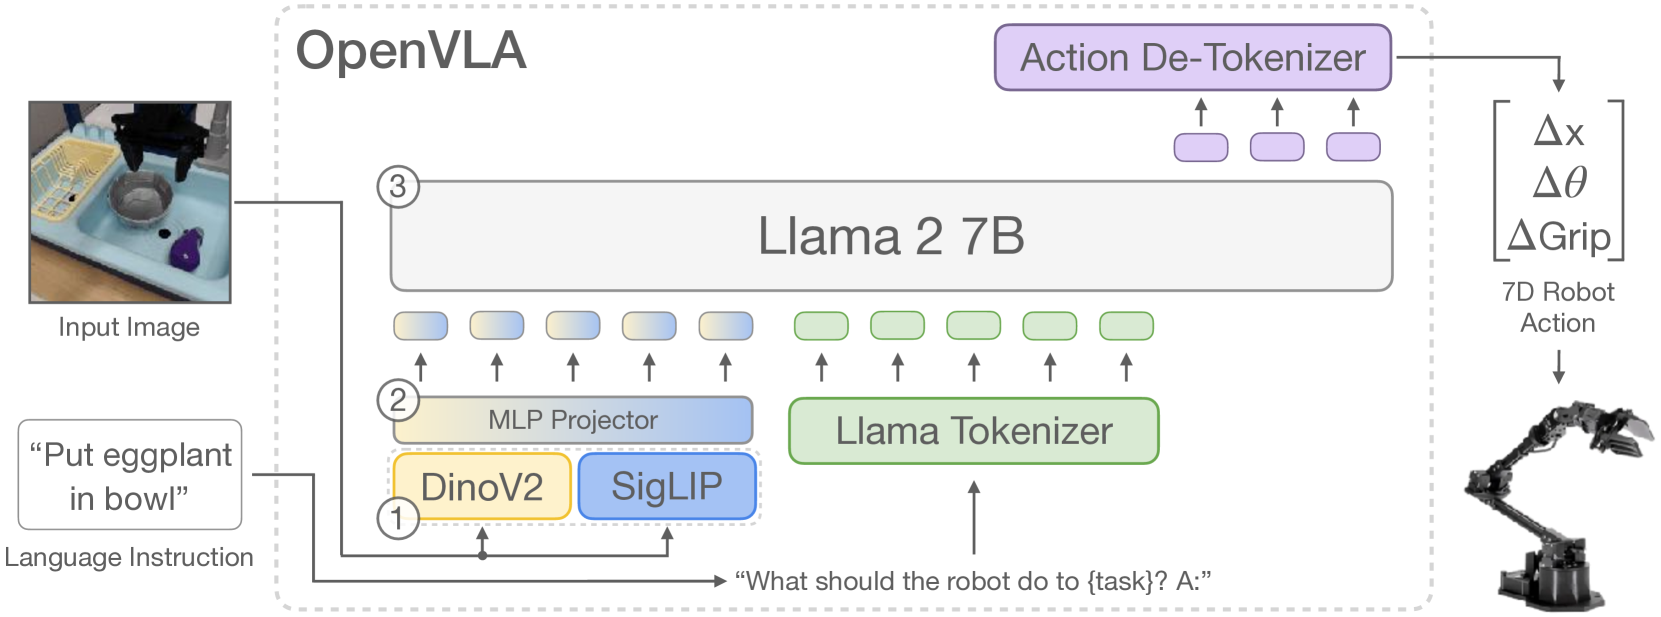
WorldFoundry vendors the Hugging Face architecture (configuration_prismatic.py, modeling_prismatic.py, processing_prismatic.py) under worldfoundry/synthesis/action_generation/openvla so inference does not depend on remote code. Two catalog variants: openvla-7b and openvla-libero-10. The in-tree runner is verified on the base card with unnorm_key=bridge_orig. The LIBERO-10 fine-tune is a pinned, staged checkpoint on the same runner; its dedicated zoo parameters are still marked planned.
Build your run
OpenVLAPipelineworldfoundry.pipelines.component_pipelinesinteractive-videoworldfoundry.evaluation.models.runners.pipeline:WorldFoundryPipelineRunnerworldfoundry-eval run \
openvla-7b \
--pipeline.task-profile interactive-video \
--jsonVariants
- StatusRunner parity pending
openvla-7bvla.action_prediction
Runtime profile
openvlaPipeline binding
openvla - StatusRunner parity pending
openvla-libero-10vla.policy_rollout
Runtime profile
openvlaPipeline binding
openvla
What it is for
Start on openvla-7b. Required inputs are image, instruction, and prompt. OpenVLAPipeline writes openvla_action_trace.json (also actions / rollout_metrics). Default unnorm key is bridge_orig — that is the verified Bridge-style route. The matching evaluation page is BridgeData V2.
Switch to openvla-libero-10 and unnorm_key=libero_10 only when the target suite is LIBERO. For the faster continuous / chunked OpenVLA line, use the sibling OpenVLA-OFT card — do not treat this page as that runtime.
Runtime contract
Default vision backbone is SigLIP 224px fused with DINOv2; language side is Llama-2 7B. Action tokens use 256 bins on ([-1, 1]), then dataset-specific de-normalization into 7-DoF. This host runs fp16 because the recorded CUDA 11.3 / torch 1.12 stack does not expose the needed bf16 ops. video is optional and unused on the recorded predict.
Pinned revisions:
openvla/openvla-7b@47a0ec7fc4ec123775a391911046cf33cf9ed83f→${WORLDFOUNDRY_HFD_ROOT}/openvla--openvla-7bopenvla/openvla-7b-finetuned-libero-10@80970322773f81baa2e22fe495d0487b93a05cfa→${WORLDFOUNDRY_HFD_ROOT}/openvla--openvla-7b-finetuned-libero-10
Running in WorldFoundry
Unified environment worldfoundry-unified-cu128 (Python 3.11, CUDA 11.3). Stage both Hugging Face trees locally, then:
worldfoundry-eval run openvla-7bunnorm_key must match the checkpoint’s data contract. License on both recorded repos is MIT.