DUSt3R
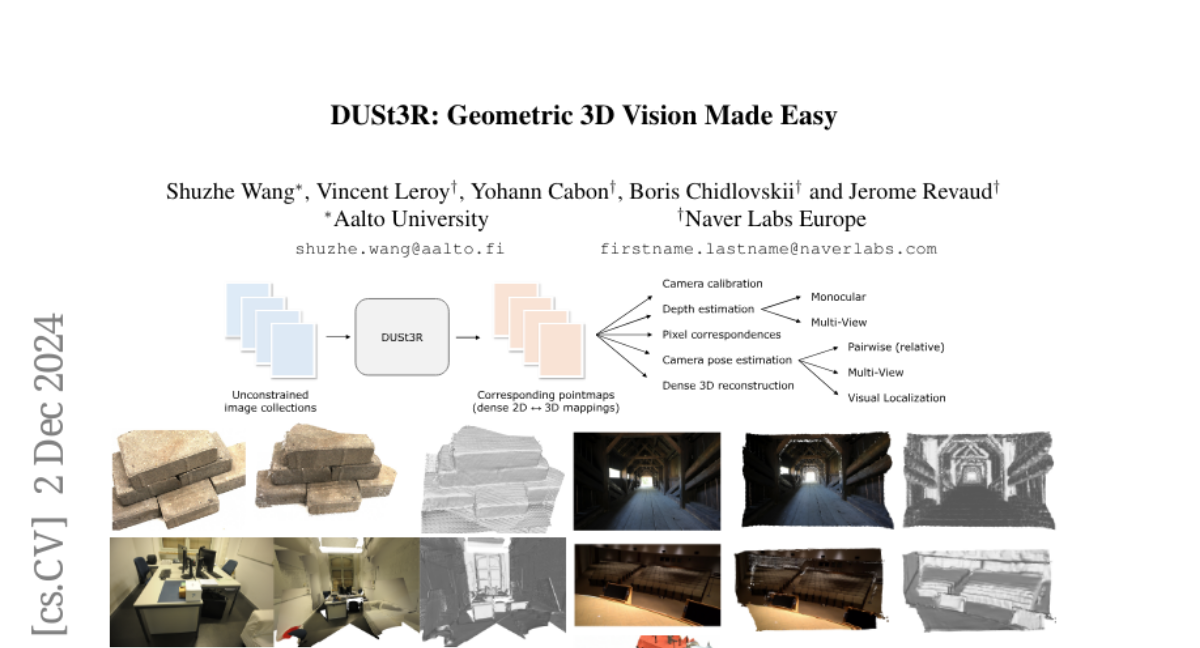
NAVER Labs 双视图点图,无需标定。捆绑多视图用例已 runner 验证。CC-BY-NC-SA-4.0。写出 dust3r_point_cloud.ply。
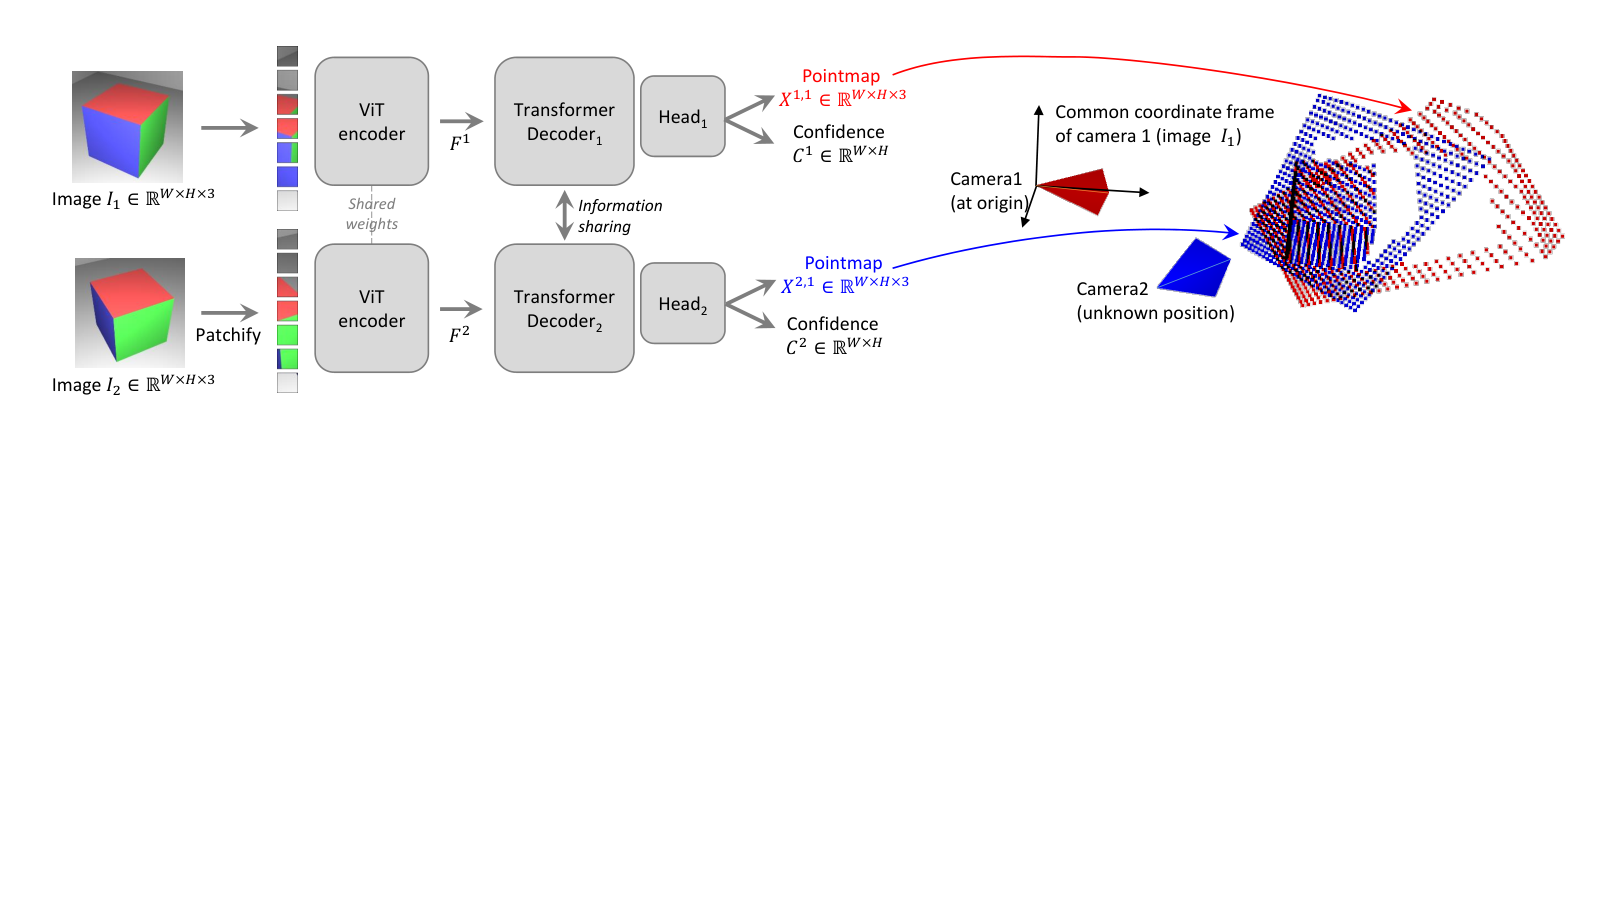
DUSt3R 让无约束双视图 3D 变简单:两张图,不要标定,不要位姿——直接回归对齐的点图。WorldFoundry 把它放在 worldfoundry/base_models/three_dimensions/general_3d/dust3r,经共享几何先验契约对外是 DUSt3RPipeline。别名 naver-dust3r、geometric-3d-vision-made-easy 解析到这里。
论文:DUSt3R: Geometric 3D Vision Made Easy(arXiv 2312.14132)。项目页:dust3r.europe.naverlabs.com。发布方:NAVER Labs Europe。许可证:CC-BY-NC-SA-4.0(下游非商用)。
Runner 已验证:checkpoint 驱动的 Studio 推理从捆绑多视图用例产出有限点云(inference_evidence.yaml)。
构建运行命令
DUSt3RPipelineworldfoundry.pipelines.geometry_priors.pipeline_geometry_priorsdefaultworldfoundry.pipelineworldfoundry-eval run \
dust3r \
--pipeline.task-profile default \
--json用来做什么
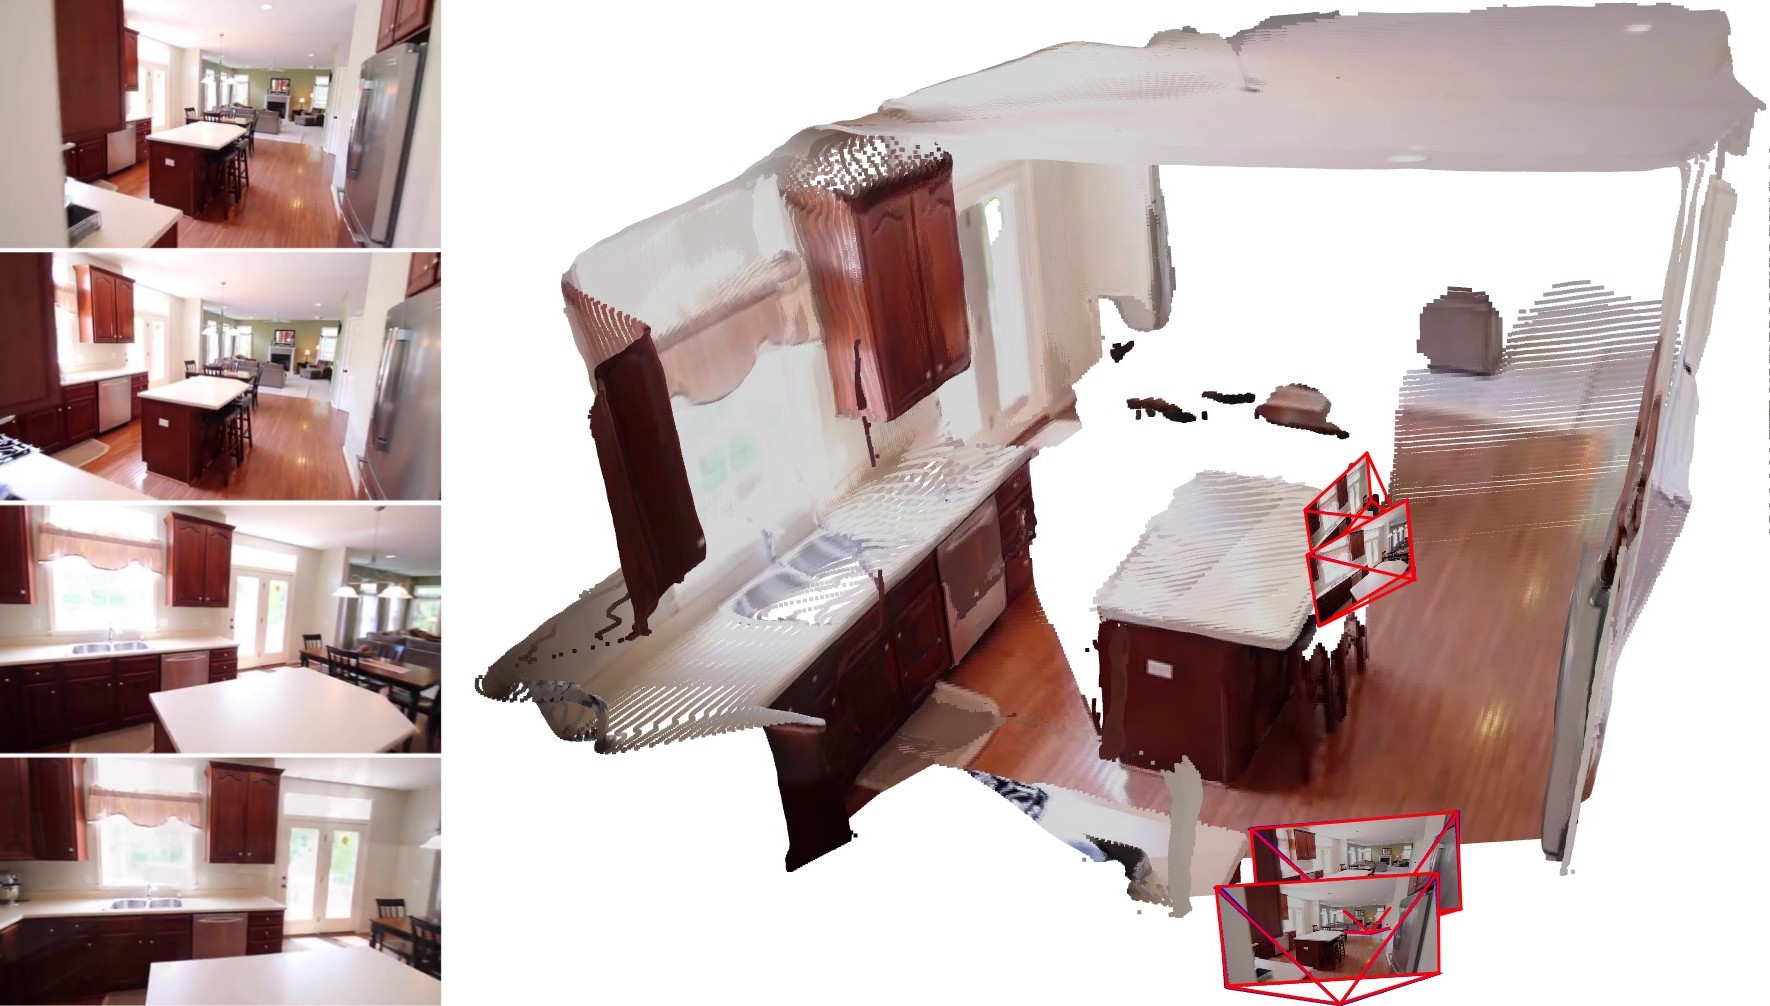
启动 worldfoundry-eval run dust3r,走前馈多视图重建 profile。必填:image。可选:prompt、video。actions:multi_view_reconstruction。产物:dust3r_point_cloud.ply。大场景仍要全局对齐,视角一多就贵。流式米制状态是 CUT3R,不是这张成对卡。
运行时契约
DUSt3RPipeline,走共享几何先验契约(dust3r-base-model)。必填:image(未标定的一对或多视图)。catalog 可选:prompt、video。actions:multi_view_reconstruction。产物:dust3r_point_cloud.ply。
| 旋钮 | 记录值 |
|---|---|
| Checkpoint | naver/DUSt3R_ViTLarge_BaseDecoder_512_dpt → $WORLDFOUNDRY_CKPT_DIR/DUSt3R_ViTLarge_BaseDecoder_512_dpt.pth |
| 编码器 | ViT-Large + Base 解码器,512 DPT |
| 成对输出 | 共享坐标系下的逐像素点图(相机 1) |
| 多视图 | 成对推理后再做全局对齐 |
| Runner | 已验证——捆绑多视图 Studio 用例产出有限点云(inference_evidence.yaml) |
环境:worldfoundry-unified-cu128(Python 3.11,CUDA 12.8)。catalog 未记录 VRAM。许可证:CC-BY-NC-SA-4.0。
在 WorldFoundry 中运行
先就位 NAVER 512_dpt 文件。缺权重会在加载时报错,运行时不会下载。下游遵守 NC-SA。